Sensor Fusion in Low-Visibility Digital Tower Operations
Fusing cameras, radar, LiDAR, and ADS-B covers each sensor's blind spots.
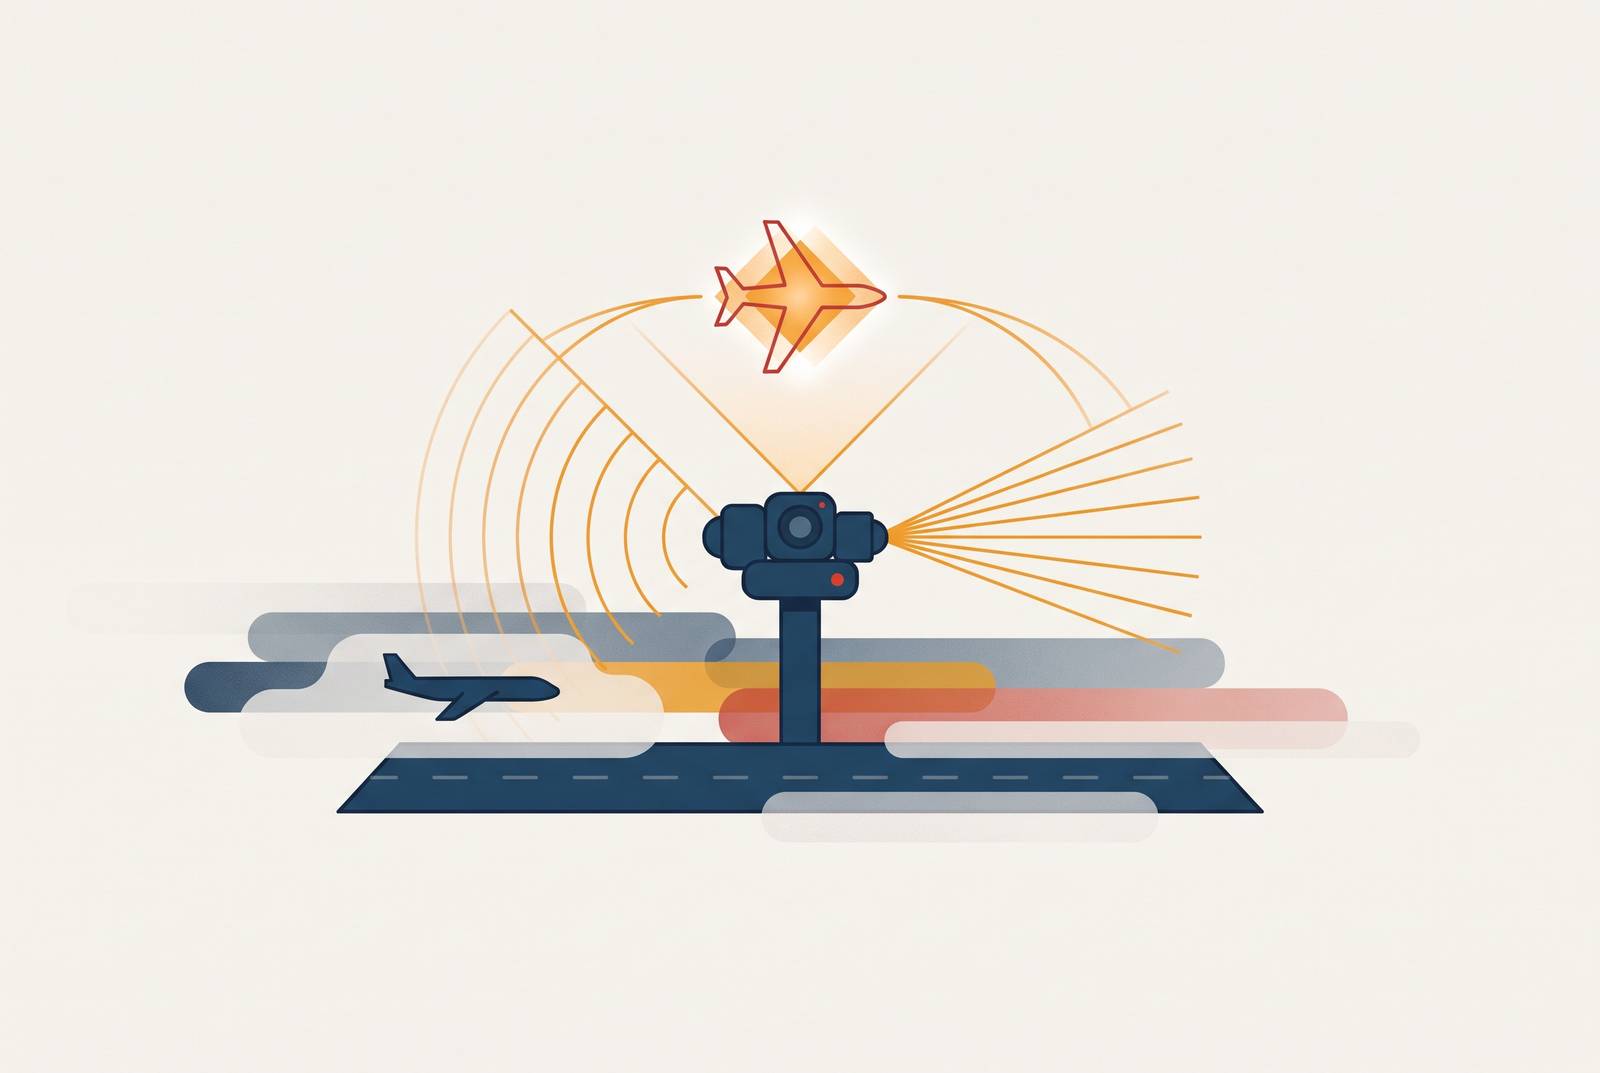
Digital ATC infrastructure for UAS and drone integration at non-towered airports depends on sensor fusion. Layering optical and infrared imagery, radar, LiDAR, and ADS-B gives controllers complementary ways to detect cooperative and non-cooperative traffic when visibility deteriorates. For airports without existing ATC coverage, this architecture provides the situational awareness needed to support mixed manned-unmanned operations, subject to validation and operational approval.
Why low-visibility conditions expose the limits of unaided human perception in ATC
Fog, rain, darkness, and long sightlines create a structural mismatch between the visual demands of airport operations and what a controller can see through glass. The picture they see is incomplete and may be unreliable, even when every piece of equipment works as it should. Better sightlines do not remove that underlying constraint. Static cameras and binoculars can extend visual range, but as passive optical instruments they remain dependent on conditions that also restrict the naked eye. In an eye-dependent system without a compensating data stream, low visibility therefore degrades the controller’s inputs without supplying another means of detection. Designs must preserve awareness when the view becomes inadequate as well as improve the view.
Why uncontrolled airports bear the sharpest edge of this risk
At a non-towered airport, there is no controller to provide a fallback when pilot self-separation fails. Low visibility makes that lack of coordination worse. Near-collisions occur twice as often when pilots have had no prior radio warning of other traffic, illustrating why the absence of communication intensifies the loss of visual information. A pilot who cannot see other traffic and has received no warning of it lacks both sources of awareness. The absence of ATC is therefore not a benign operating condition when those safeguards fail together.
The vast majority of U.S. airports operate without a tower, making this the largest single coverage gap in the National Airspace System. Many small airports cannot afford either the construction of a traditional tower or the staffing needed to operate it. A solution dependent on the same building and staffing model would leave the underlying coverage problem unresolved. The practical requirement is consequently a more affordable form of ATC infrastructure that can provide dependable surveillance rather than merely a less expensive observation point.
What sensor fusion is and why a single modality cannot replace it
No individual sensor can provide reliable detection under every condition that restricts airport visibility. Each has a distinct physical limit. Infrared and FLIR cameras perform well in darkness and light fog, but heavy fog can prevent them from identifying required visual references. Millimeter-wave radar is more robust in fog than cameras and LiDAR, but it cannot resolve fine object detail. LiDAR provides precise three-dimensional spatial information, yet precipitation and airborne particulates degrade it. ADS-B supplies accurate aircraft data only when the target is equipped and broadcasting.
Sensor fusion combines data streams from these physically different modalities into one situational picture. A complementary sensor supplies information where another has a blind spot, reducing dependence on any one method of detection. This distinguishes a fused architecture from a collection of separate feeds that leaves the controller to reconcile their limitations. The combined output can represent traffic and its movement in ways no single input could support alone.
2026 research on adaptive sensor fusion systems found that a camera-only approach achieved just a 16.7% detection rate in heavy fog. That finding illustrates the limits of optical-only detection. It does not establish that every other sensor performs equally well in the same conditions, or that adding sensors automatically produces a safe system. Design evaluation must establish whether the combination closes detection gaps, regardless of one instrument’s strong performance in favorable conditions.
How each sensor modality contributes its piece of the picture
High-resolution day cameras provide photographic-quality imagery in good conditions and form the baseline visual reference for most operations. Infrared and FLIR cameras add to that reference by detecting heat signatures without depending on ambient light. These cameras work well in darkness, light precipitation, and partial fog, so they offer another way to see when visible-light imagery is less useful. The Digital Tower Technology Coalition (DTTC) names infrared imagery as one of the tools for low visibility in the FAA’s digital tower systems now in use.
Millimeter-wave radar adds active sensing to that visual layer, illuminating the airfield and returning position and movement data. It complements FLIR when dense fog degrades passive thermal imaging. LiDAR adds a different kind of spatial precision. Its three-dimensional point clouds map the airfield surface and support precise positional tracking of aircraft and vehicles on the ground. The deployed military DVEPS program demonstrates that fused FLIR and LiDAR can produce a synthetic three-dimensional view adequate for safe operations in zero-visibility conditions, including dust, fog, smoke, rain, snow, and darkness. That provides practical evidence for the combination, while an airport implementation still requires validation.
ADS-B adds the position, track, and ground speed broadcast by equipped aircraft, which gives the surveillance picture a cooperative data layer. That layer does not cover non-broadcasting targets. Smart overlays turn fused sensor information into annotated displays of aircraft positions, runway data, and weather. Live airfield audio adds the local soundscape for a remotely located controller. Audio is a recognized part of the situational awareness architecture and preserves information that imagery alone does not convey.
How fusing ADS-B with radar improves tower-range surveillance specifically
Tower-range surveillance places different demands on data than en-route or terminal-area surveillance. Controllers need precise positions to detect deviations from glide or localizer paths, as well as frequent updates during final approach and landing. Speed can change quickly during these phases. A long update interval can obscure changes in aircraft speed and spacing, creating the potential for misjudgment and inappropriate handling.
The paper presented to ICAO’s APAC ATMAS TF/6, “Research on the Fusion of ADS-B and Approach Radar Within Tower Range,” draws on experience at Tianfu Airport. It compares approach radar on its own with radar fused with ADS-B. The paper reports improved track position accuracy and ground speed calculation, a lower false-alarm rate, and more frequent updates from the fused approach. These improvements give tower controllers the data they need as well as extending surveillance coverage. A target’s reported position becomes more useful when its speed and recent movement are also represented reliably.
ADS-B provides high precision and fast updates at a lower upfront cost than wide-area multilateration. It is therefore a cost-effective supplement to radar. The two inputs serve different surveillance roles. Fusing them covers more space with more frequent updates and gives a better picture of position, track, and speed than radar alone. The cooperative limitation nevertheless remains, so the benefits demonstrated at Tianfu do not justify treating ADS-B as a replacement for detecting non-broadcasting traffic.
What the first operational U.S. digital towers reveal about the sensor fusion architecture in practice
The FAA announced in November 2026 that the first operational U.S. digital ATC towers were serving Bartow Executive Airport (KBOW) in Florida and Kenai Municipal Airport (PAEN) in Alaska. These were the first under its newly approved digital tower program. The FAA describes advanced cameras and digital displays providing a continuous, 360-degree view of runways, taxiways, and surrounding airspace. The DTTC lists blind-spot elimination, infrared imagery, automatic aircraft detection with on-screen data tags, and live airfield sound among the tools now in use.
Camera arrays cover the sightlines, infrared helps controllers see in low visibility, and automatic detection with data tags shows aircraft information on the display. Live sound supplements the remote visual picture. However, this list of tools does not show that every tower in use has every modality discussed here. The operational evidence supports the use of complementary sensing and presentation tools, rather than a claim that one universal hardware stack has been approved for all airports.
The FAA names five airports that are now non-towered and next in line for digital towers. They are Winter Haven Regional (KGIF) and Venice Municipal (KVNC) in Florida, Montgomery County Airpark (KGAI) in Maryland, Johnston Regional (KJNX) in North Carolina, and Durango-La Plata County Airport (KDRO) in Colorado. The FAA also requires a closed, physically point-to-point network and an independent fiber optic telecommunication feed between the sensor mast and the Digital Tower Center. That requirement makes the data connection part of the operational infrastructure.
How can airports without a control tower gain situational awareness for drone traffic?
At an airport that has never had ATC, a fused digital tower creates the surveillance picture. A traditional tower supplies elevated sightlines and professional judgment, but an eye-dependent design still loses detection capability when visibility deteriorates. A digital installation can introduce multiple sensing methods from the outset, including redundancy that some larger facilities lack. Its value lies in the completeness of that coverage.
For nearby UAS operations, the central requirement is detection of both cooperative and non-cooperative low-altitude targets despite degraded visibility. Radar, infrared, and LiDAR supply complementary detection and spatial information that does not depend solely on an aircraft broadcasting its position. 2026 research found that adaptive sensor fusion achieved a 316.7% improvement in detection range in heavy fog compared with a single-sensor baseline. That result supports the fusion approach, while remaining distinct from proof that a particular airport installation is approved to manage mixed manned-unmanned traffic.
The economics make this architecture relevant to small airports. A remote sensor installation costs much less than a physical tower, and facilities that share a remote operations center can share its capital and staffing costs. Internationally, controllers can be certified for multiple airports while controlling only one at a time. The FAA’s September 2026 certification, however, covers single-airport, single-runway operations, so shared-center potential should not be confused with the scope of that approval. Air navigation service providers have also found that digital environments supporting multiple airports attract younger recruits and reduce controller workload and stress. Affordability and workforce flexibility can thus support wider coverage without making reduced sensing capability the price of access.
What it takes to validate and certify a sensor fusion architecture for NAS operations
The FAA’s System Design Approval (SDA) is required before a digital or remote ATC tower system can operate in the National Airspace System. The process is both lengthy and expensive. It typically takes approximately 24 to 36 months, depending on product maturity and the engineering documentation supporting development. Testing has historically taken place at FAA facilities such as the William J. Hughes Technical Center, with the testbed at the National Aerospace Research and Technology Park near Atlantic City, New Jersey. Systems must demonstrate performance in controlled conditions before field deployment.
For a fused architecture, approval concerns the combined system rather than a set of individual sensor specifications. Strong component performance is not enough on its own. The integrated modalities must meet the FAA’s safety, accuracy, and reliability requirements, including the performance of the situational picture they produce together. This is the step that connects sensing capability with operational use. It also makes development maturity and documentation consequential for both deployment schedules and the cost of reaching small airports.
The 2024 FAA Reauthorization Act directed the agency to establish a clear framework for approving and deploying digital towers. Initial deployments beginning in September 2026, followed by the November announcement, mark the first operational results of that mandate. The DTTC, formed earlier in 2026, is advocating for federal funding and FAA approvals while working on enhanced visual detection tools and design and approval practices. The pathway is open, but access still has costs. Validated sensor combinations and initial tower approvals establish a route toward broader deployment, while the remaining time and funding constraints reinforce the need for affordable, purpose-built systems that can reach airports without ATC coverage.